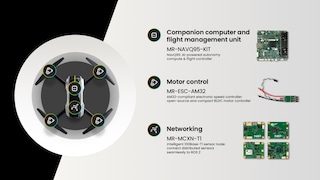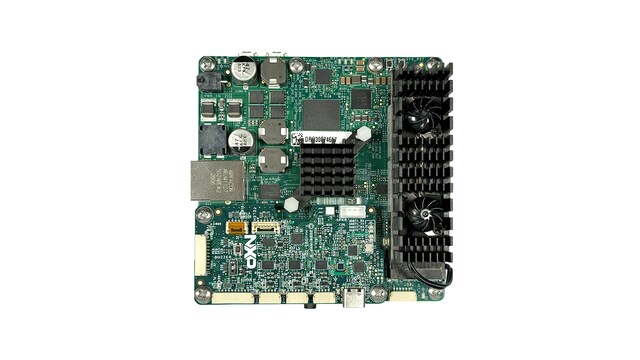
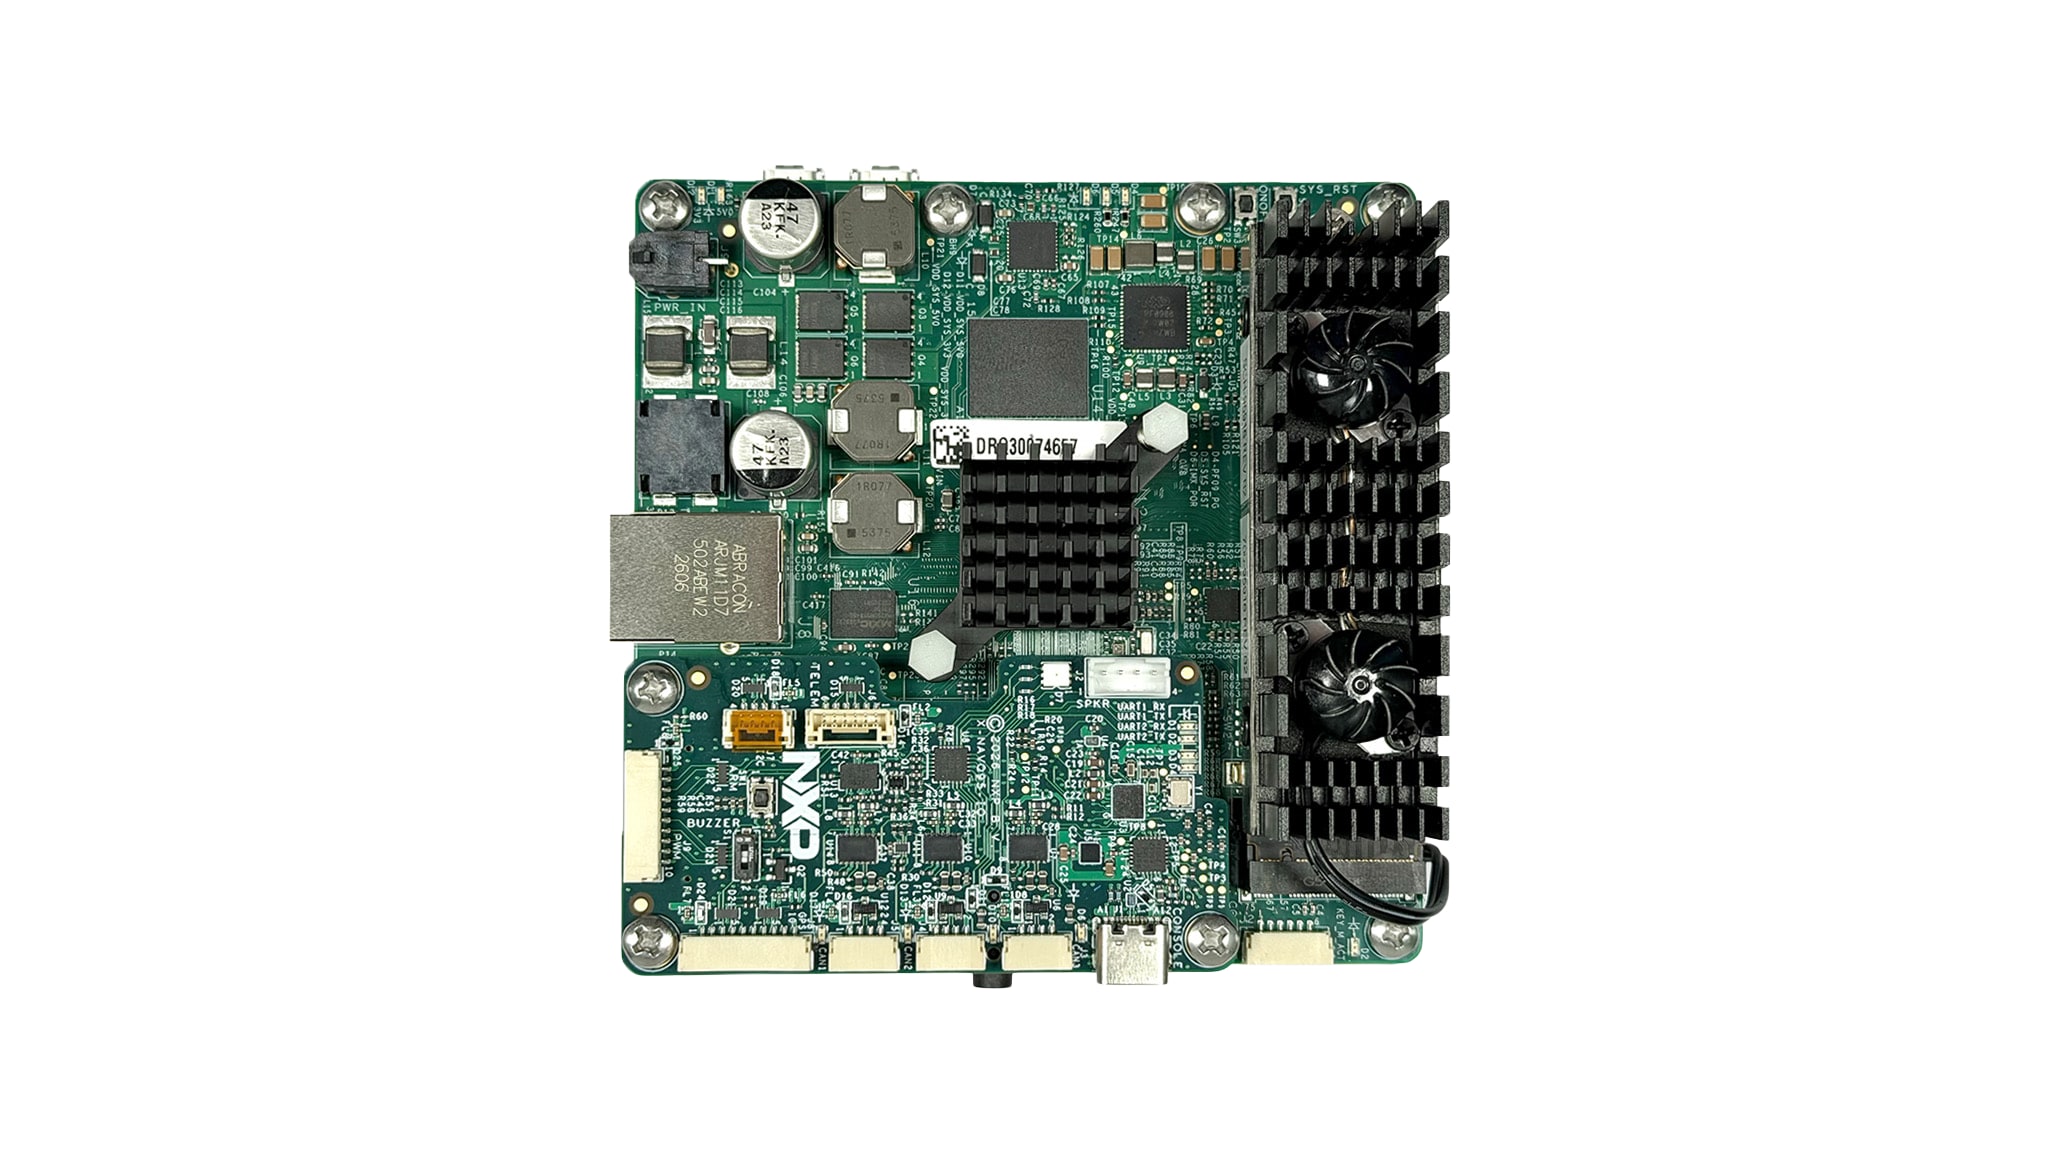
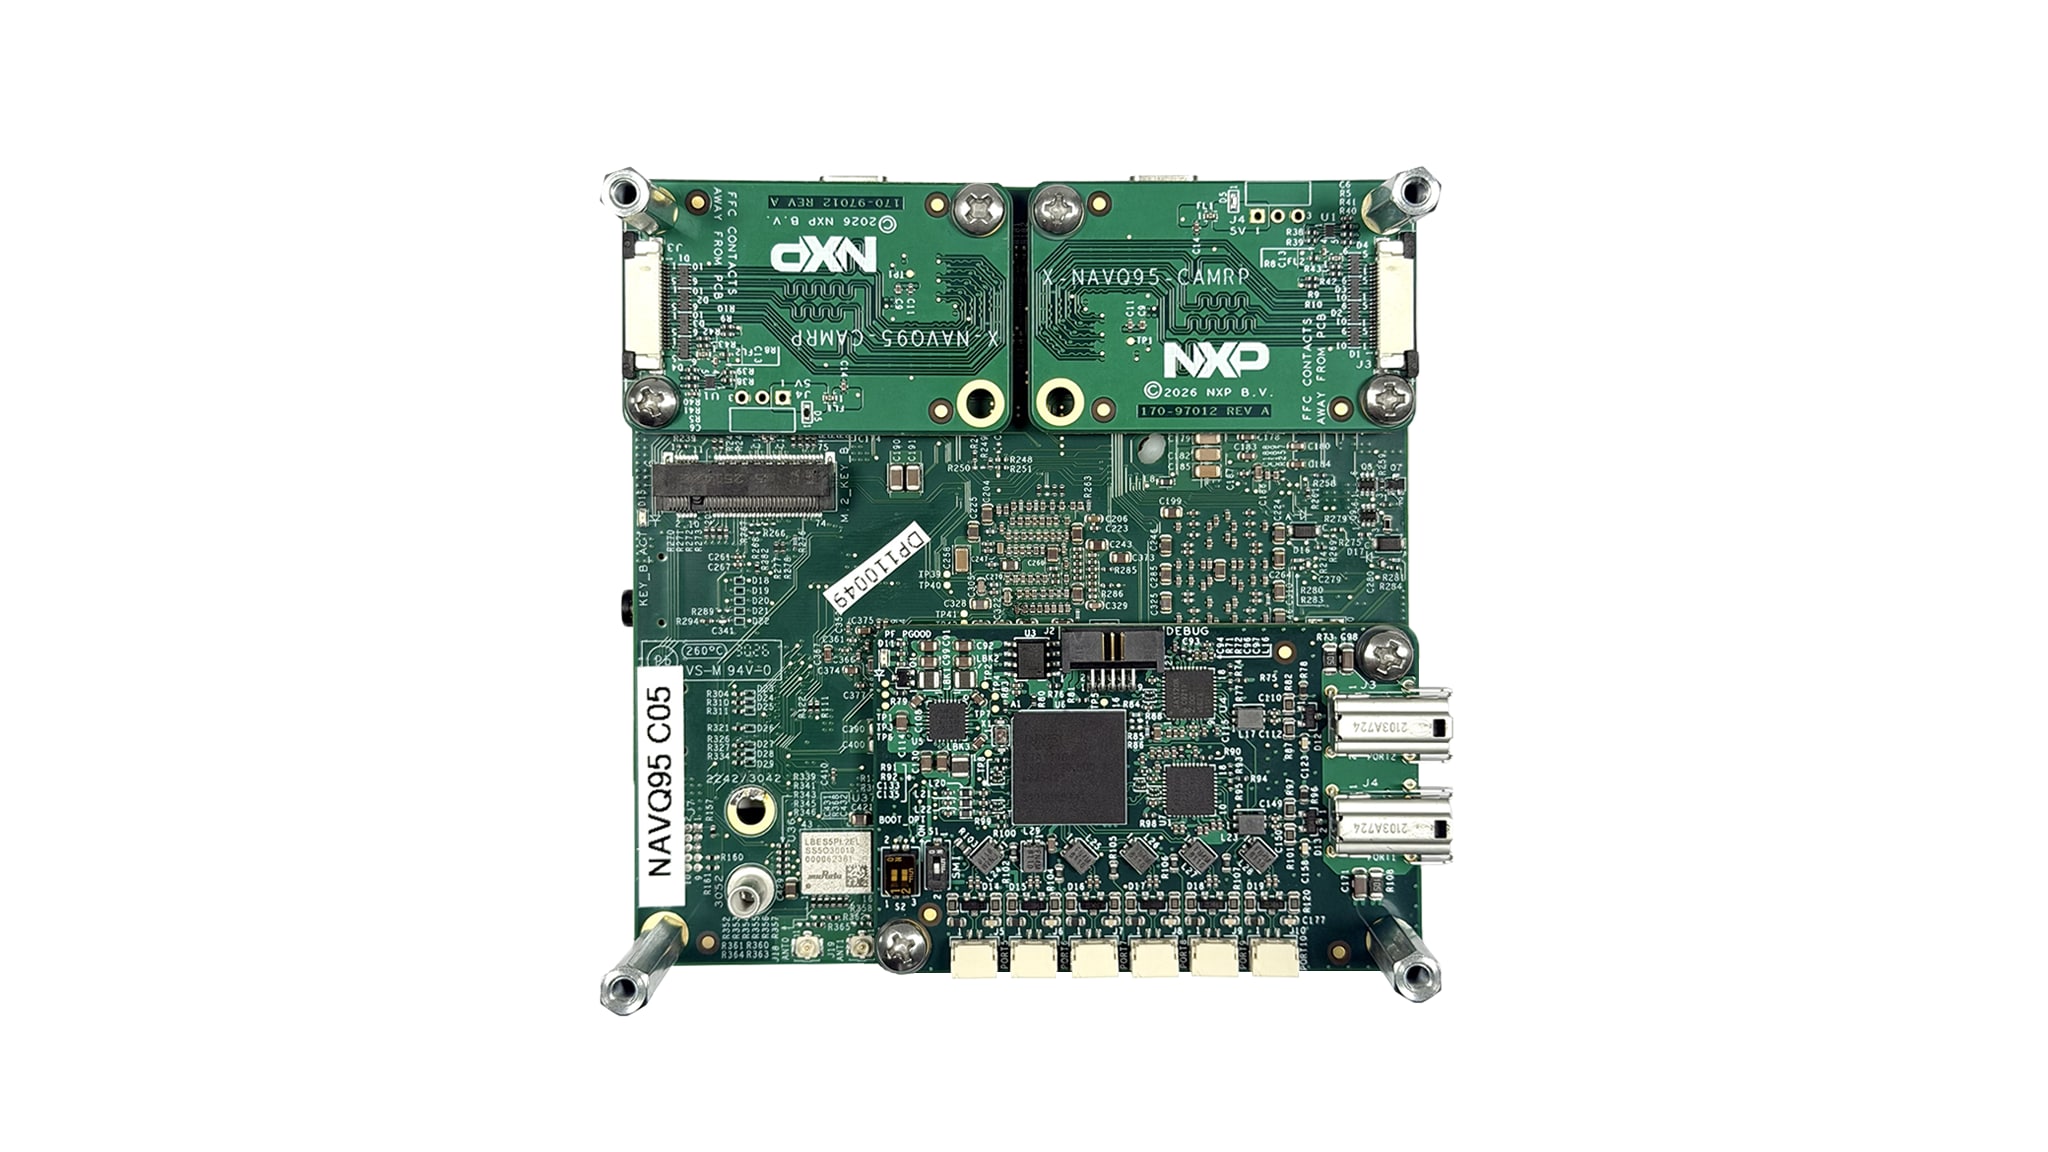
NavQ95: AI-Powered Autonomy Compute and Flight Controller

  • 本ページには、試作段階の製品に関する情報が含まれています。記載されている仕様および情報は、予告なく変更される場合があります。詳細については、担当営業までお問い合わせください。

画像をクリックすると拡大します。

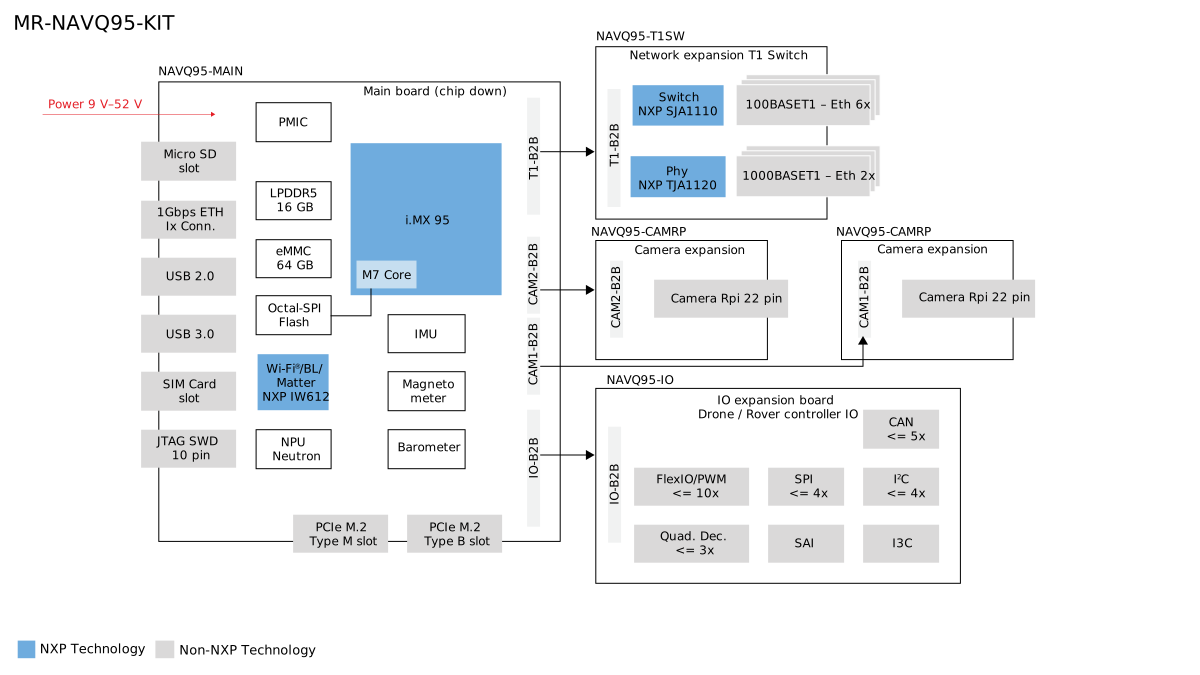
ブロック図

MR-NAVQ95 Block Diagram

MR-NAVQ95 Block Diagram

Features

Benefits

  • Reduce SWaP (Size, Weight and Power) and complexity system by combining flight controller, companion computing and AI on one platform
  • Enable intelligent autonomy with onboard AI perception and decision-making
  • Accelerate development with open-source hardware and software
  • Scale AI performance through PCIe-based acceleration interface (Ara-Ready) without redesigning the core platform
  • Enable connected operations through high-speed networking connectivity

System Features

  • Open Source Design: Open Source OS image available based on Yocto with Ubuntu 24.04 and ROS 2 Jazzy
  • Flight stacks: PX4 & Cognipilot
  • i.MX 95, Hexa core ARM A55, M7 & M33 real time core
  • Neutron NPU, 32 Mb eMMC, 16 Gb RAM for complex SLAM / navigation algorithm
  • Special execute in-place (XIP) memory for real time flight control
  • Up to 60V power input
  • Swappable I/O boards. 2x IMU, Magnetometer, Barometer, 2x PCIe
  • Support for 6 PWM out ports running Dshot 600
  • Example code to do Vision AI via Neutron or Ara240 from a defined mipi-CSI fixed focus camera with 1080p and 30fps and 20ms latency

ドキュメント

クイック・リファレンス ドキュメンテーションの種類

1 ドキュメント

コンパクトリスト

設計・リソース

Related Hardware

クイック・リファレンス ボードタイプ.

4 ハードウェア提供

デザイン・ファイル

クイック・リファレンス 設計・ファイルの種類.

1 設計・ファイル

ソフトウェア

クイック・リファレンス ソフトウェア・タイプ.

1 ソフトウェア・ファイル

注: より快適にご利用いただくために、ソフトウェアのダウンロードはデスクトップで行うことを推奨します。
サポート

お困りのことは何ですか??